What Is an EV Motor Resolver? Rotor Position, Torque Control and Faults
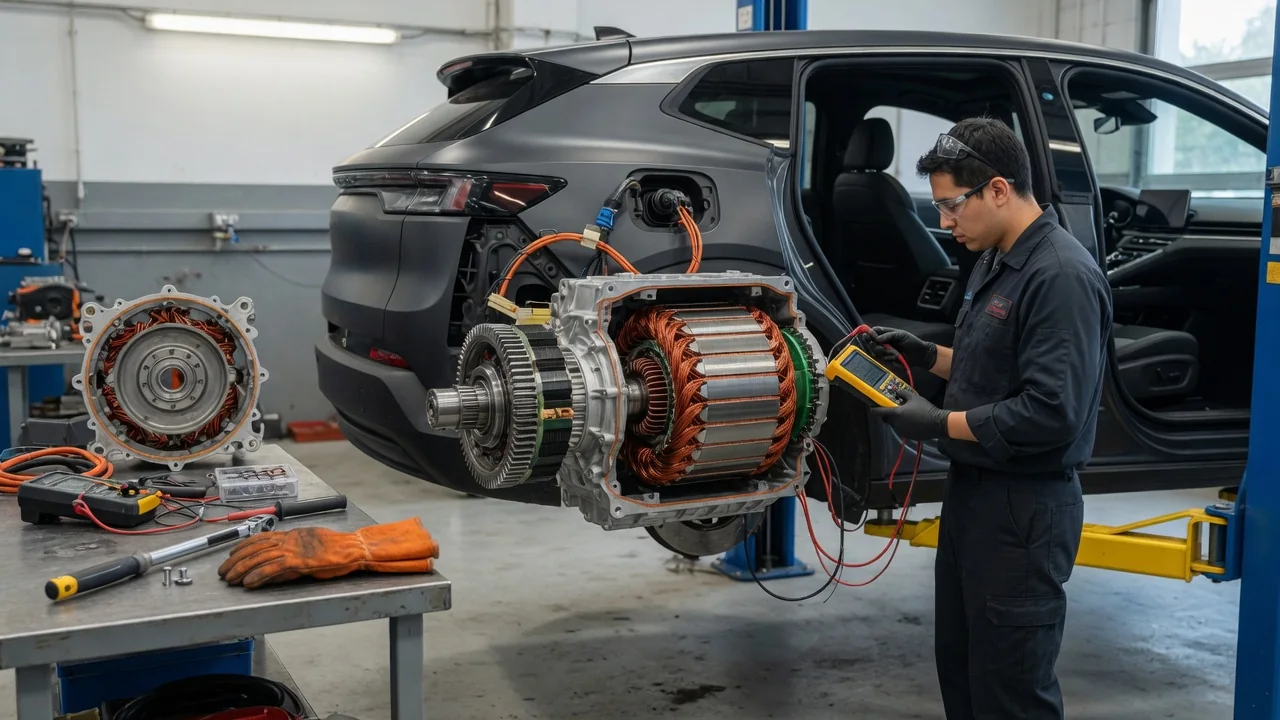
An EV motor resolver is the sensor that tells the inverter where the motor's rotor is pointing at every instant. Without that information, the inverter could not time the current it sends to the stator windings, and the motor would not produce smooth, predictable torque. This guide explains what an electric motor resolver sensor measures, how the inverter uses its signal for torque control, which faults tend to affect it, and what that means for owners and technicians.
Rotor Position: What the Resolver Measures
A resolver is essentially a rotary transformer. Its stationary part carries an excitation winding and two output windings placed 90 electrical degrees apart, usually called the sine and cosine windings. The rotating part is attached to the motor shaft. In many automotive designs it is a variable-reluctance type, meaning the rotor is simply a shaped stack of steel laminations with no windings, magnets or electronics of its own. Nothing on the rotating side needs power or brushes, which keeps the sensor mechanically simple.
The inverter feeds the excitation winding with a high-frequency alternating signal. As the shaped rotor turns, the magnetic coupling between the excitation winding and each output winding changes. The result is two output signals whose amplitudes rise and fall with the sine and cosine of the rotor angle. The controller demodulates these signals and calculates the angle from their ratio. Because the angle comes from a ratio rather than a single amplitude, slow changes that affect both windings equally, such as temperature drift, have less influence on the result. Tracking how quickly the angle changes also gives rotor speed and direction.
This approach suits the environment inside an electric drive unit. A resolver tolerates heat, vibration, oil mist and electrical noise better than many optical or electronic position sensors, since it contains only copper windings and steel. It also reports position when the rotor is stationary, so the inverter knows the angle the moment the vehicle is switched on, before the motor has turned at all.
Torque Control: How the Inverter Uses the Signal
In a permanent-magnet synchronous motor, torque depends on the angle between the magnetic field created by the stator currents and the field of the rotor magnets. Inverters commonly use a method called field-oriented control. Using the rotor angle, the controller mathematically converts the measured phase currents into two components aligned with the rotor: one that produces torque and one that strengthens or weakens the magnetic field. The torque-producing component is regulated to meet the requested torque, while the field component is used, among other things, to extend the motor's usable speed range.
In practice, the vehicle controller turns accelerator pedal position and driving conditions into a torque request. The inverter translates that request into current targets, compares them with the measured phase currents, and switches its power transistors to shape the voltage applied to each winding. This loop repeats continuously at high speed, and every cycle relies on a fresh rotor angle. The same process runs in reverse during regenerative braking, when the inverter commands negative torque so the motor acts as a generator.
Accuracy matters because the angle defines where the inverter places current. A small error shifts current away from the ideal position, so the motor makes less torque per amp and generates more heat. Errors that vary as the rotor turns can show up as torque ripple, vibration or audible whine. The mechanical relationship between the resolver and the rotor magnets must also be known, so the controller stores an offset value. A badly wrong offset can reduce torque sharply, and in extreme cases the motor may push in an unintended direction, which is why controllers check the signal for plausibility.
Faults: What Can Go Wrong
Electrical problems are the most common category of resolver trouble in general terms. Possible causes include an open or shorted winding, a chafed harness, corroded or loose connector terminals, damaged cable shielding, and failures in the inverter circuits that generate the excitation signal or read the outputs. Intermittent connection faults can be especially difficult because they may appear only when components are hot, cold or vibrating.
Mechanical and magnetic issues also affect the signal. A rotor target that has shifted on the shaft, a change in air gap caused by bearing wear or damage, incorrect positioning after a repair, or metallic debris near the sensor can all distort the sine and cosine outputs. Strong electrical interference from nearby high-voltage cables can corrupt the signal if shielding or grounding is compromised.
Controllers typically monitor the resolver continuously. Checks may include whether the combined amplitude of the sine and cosine signals stays within an expected band, whether the excitation signal is present, and whether the calculated angle and speed are plausible. When a check fails, the system usually stores a diagnostic trouble code, turns on a warning indicator and limits or disables motor output. The exact response varies by vehicle. Symptoms a driver might notice include jerky acceleration, shudder, unusual motor noise, reduced power, sudden loss of propulsion or a vehicle that will not enter its ready-to-drive state.
Practical Implications and Limits
For owners, the resolver is not a maintenance item. It is usually sealed inside the motor or drive unit housing and has no service interval or visual inspection point. Its failure symptoms also overlap with problems in phase current sensors, the inverter itself, motor windings or software, so a warning light or a single code does not prove the resolver is at fault. Proper diagnosis relies on the manufacturer's service information, scan tool data and the specified resistance and signal checks for that vehicle.
Repair approaches differ between designs. Some drive units allow the resolver to be replaced separately, while others treat it as part of the motor assembly. After replacing a resolver, motor or inverter, many manufacturers call for an offset learning or calibration procedure with a scan tool; skipping it can leave the motor performing poorly or setting new faults. Because the work involves components connected to high-voltage systems, it should follow the manufacturer's de-energizing procedure and be performed only by appropriately trained technicians.
It also helps to understand what the resolver does not do. It does not measure torque, current or motor temperature; it supplies only angle and the speed derived from it. Some controllers can estimate rotor position without a sensor under certain operating conditions, but whether a given vehicle can keep moving after a resolver fault, and how far or how fast, is specific to its design. The principles in this article are general and should be paired with vehicle-specific information for any real diagnosis.